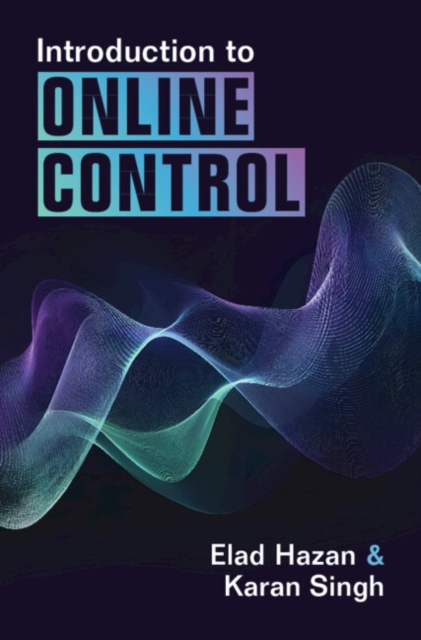
Introduction to Online Control
ourprice £48.00
| Author | Elad Hazan |
|---|---|
| Format | Hardback |
| Publisher | Cambridge University Press |
| Publication Date | 2026-03-26 |
| Pages | 174 |
| ISBN-13 | 9781009499668 |
In stock
Description
This tutorial guide introduces online nonstochastic control, an emerging paradigm in control of dynamical systems and differentiable reinforcement learning that applies techniques from online convex optimization and convex relaxations to obtain new methods with provable guarantees for classical settings in optimal and robust control. In optimal control, robust control, and other control methodologies that assume stochastic noise, the goal is to perform comparably to an offline optimal strategy. In online control, both cost functions and perturbations from the assumed dynamical model are chosen by an adversary. Thus, the optimal policy is not defined a priori and the goal is to attain low regret against the best policy in hindsight from a benchmark class of policies. The resulting methods are based on iterative mathematical optimization algorithms and are accompanied by finite-time regret and computational complexity guarantees. This book is ideal for graduate students and researchers interested in bridging classical control theory and modern machine learning.
Additional information
| Weight | 0.406 kg |
|---|---|
| Dimensions | 1.8 × 23.7 × 16.1 cm |
| Author | Elad Hazan |
| Publisher | Cambridge University Press |
| Imprint | Cambridge University Press |
| Format | Hardback |
| ISBN-13 | 9781009499668 |
| Publication Date | 2026-03-26 |
| Publication Year | 2026 |
| Pages | 174 |
| Country of Publication | GB |
| Language | English |
Related products
-

Mallowan’s Memoirs: Agatha and the Archaeologist
ourprice £10.99 Add to cart -
John Lennon: The Life
ourprice £14.99 Add to cart -
Born to Be Posthumous: The Eccentric Life and Mysterious Genius of Edward Gorey
ourprice £9.99 Add to cart -
Fatherland: A Memoir of War, Conscience and Family Secrets
ourprice £25.00 Add to cart


Reviews
There are no reviews yet.